My robots
Robots built over the years: a maze solver, a mini sumo, a hexapod and three half-pound combat robots for OSHWDem.
- Status
- Workshop and competition projects
The robots
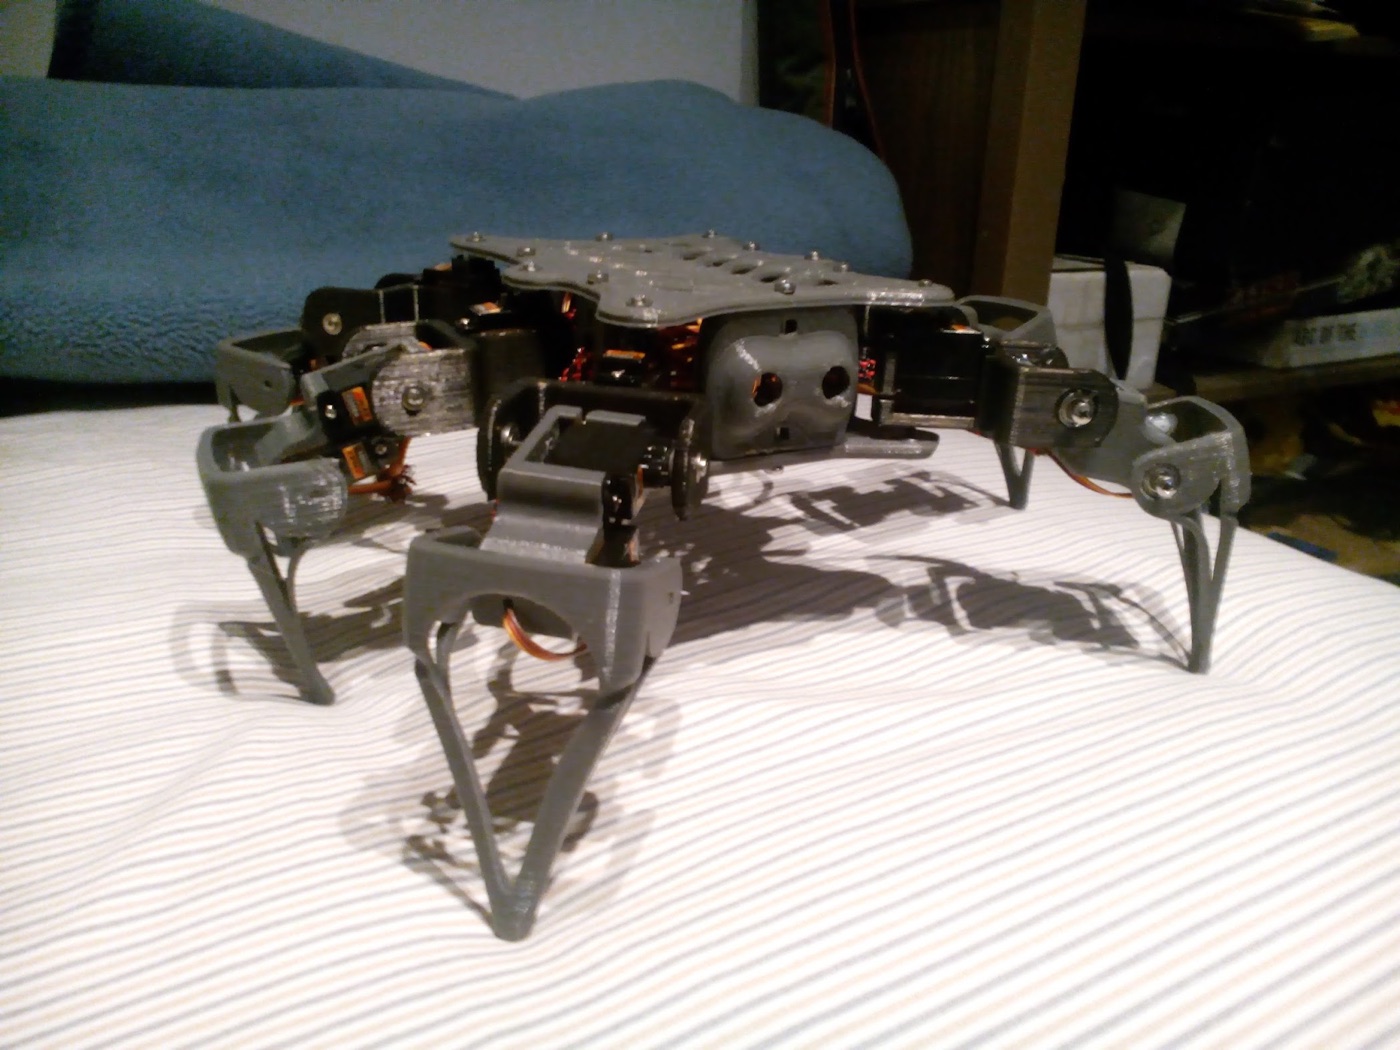
Hexapod
An 18-degree-of-freedom hexapod, three servos per leg, built from an open design on Thingiverse.
- Parts 3D printed from the published design, with a servo at every joint.
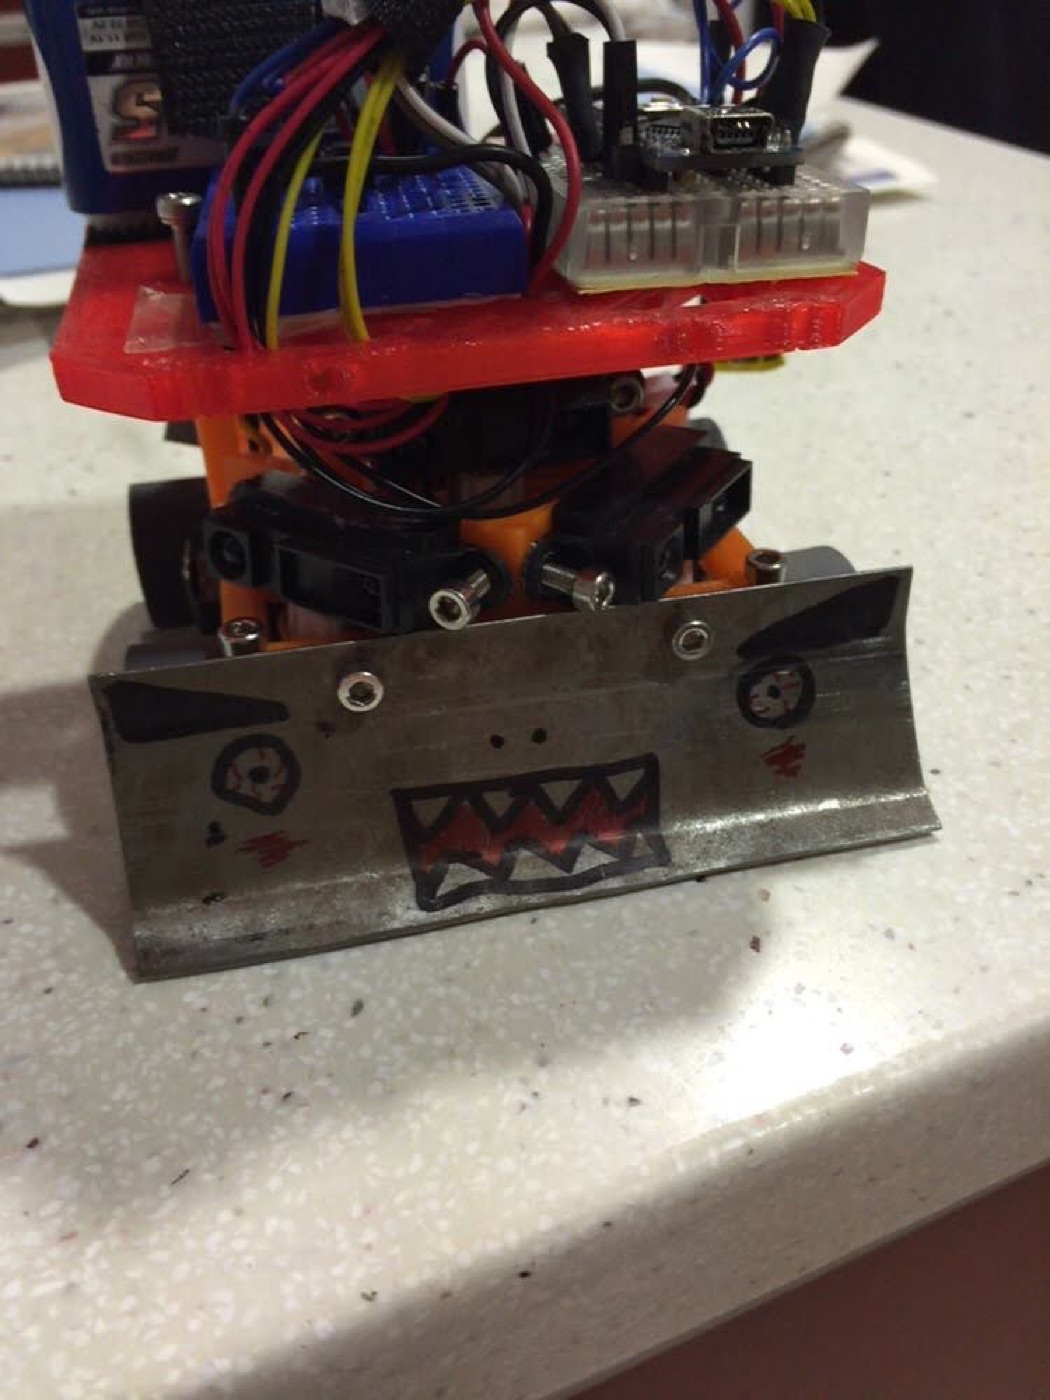
Mini sumo
Mini sumo robot that finds its opponent with distance sensors and pushes it out of the ring.
- Arduino Nano, four-wheel drive and Sharp infrared distance sensors at the front and sides.
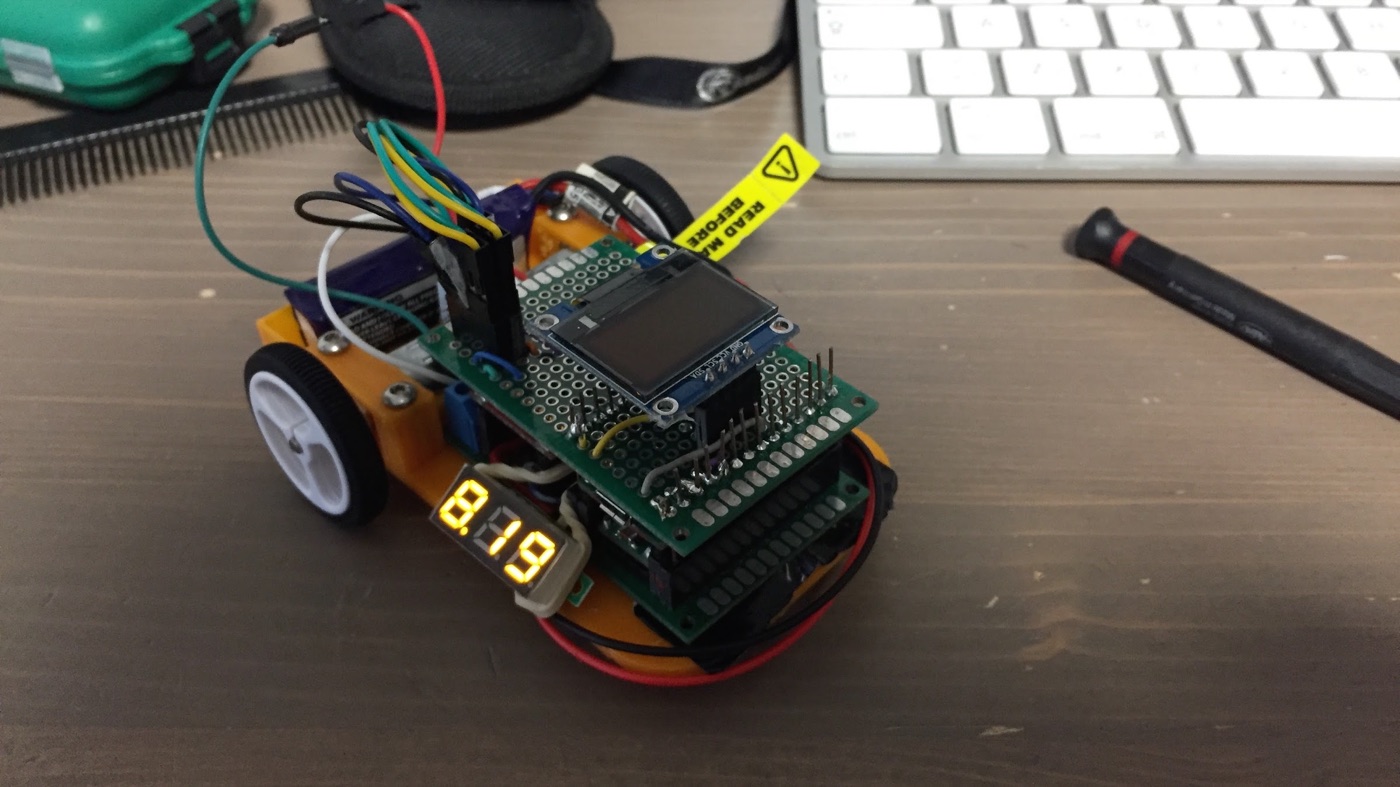
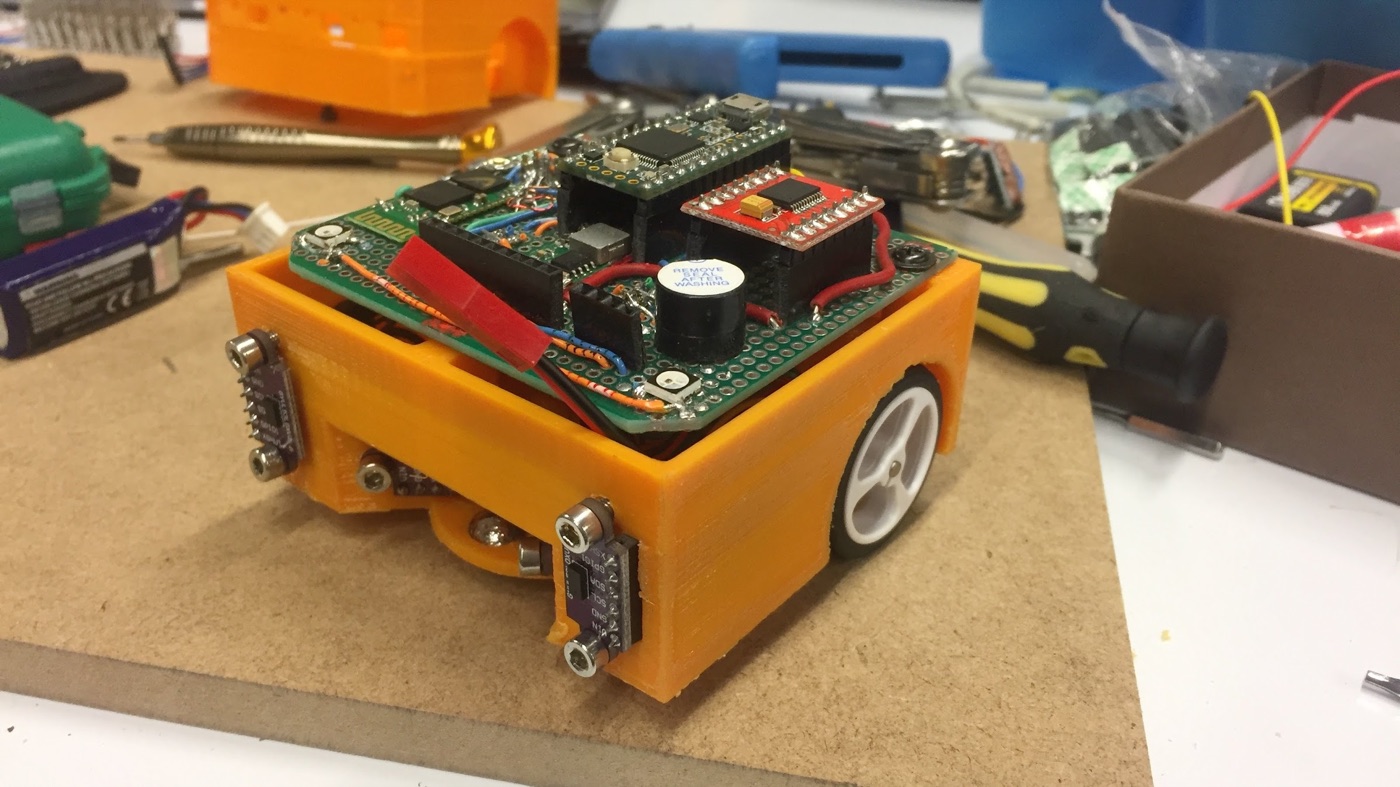
SuperMaze
Robot for the OSHWDem maze contest: it explores the maze, maps it and finds the way to the goal.
- Teensy 3.1 programmed with PlatformIO, four VL53L0X laser distance sensors, an MPU9250 IMU and motor encoders.
- Flood-fill maze map and PID controllers for turning, speed and distance to the walls.
- Telemetry and commands over Bluetooth, plus an OLED screen to debug on the track.
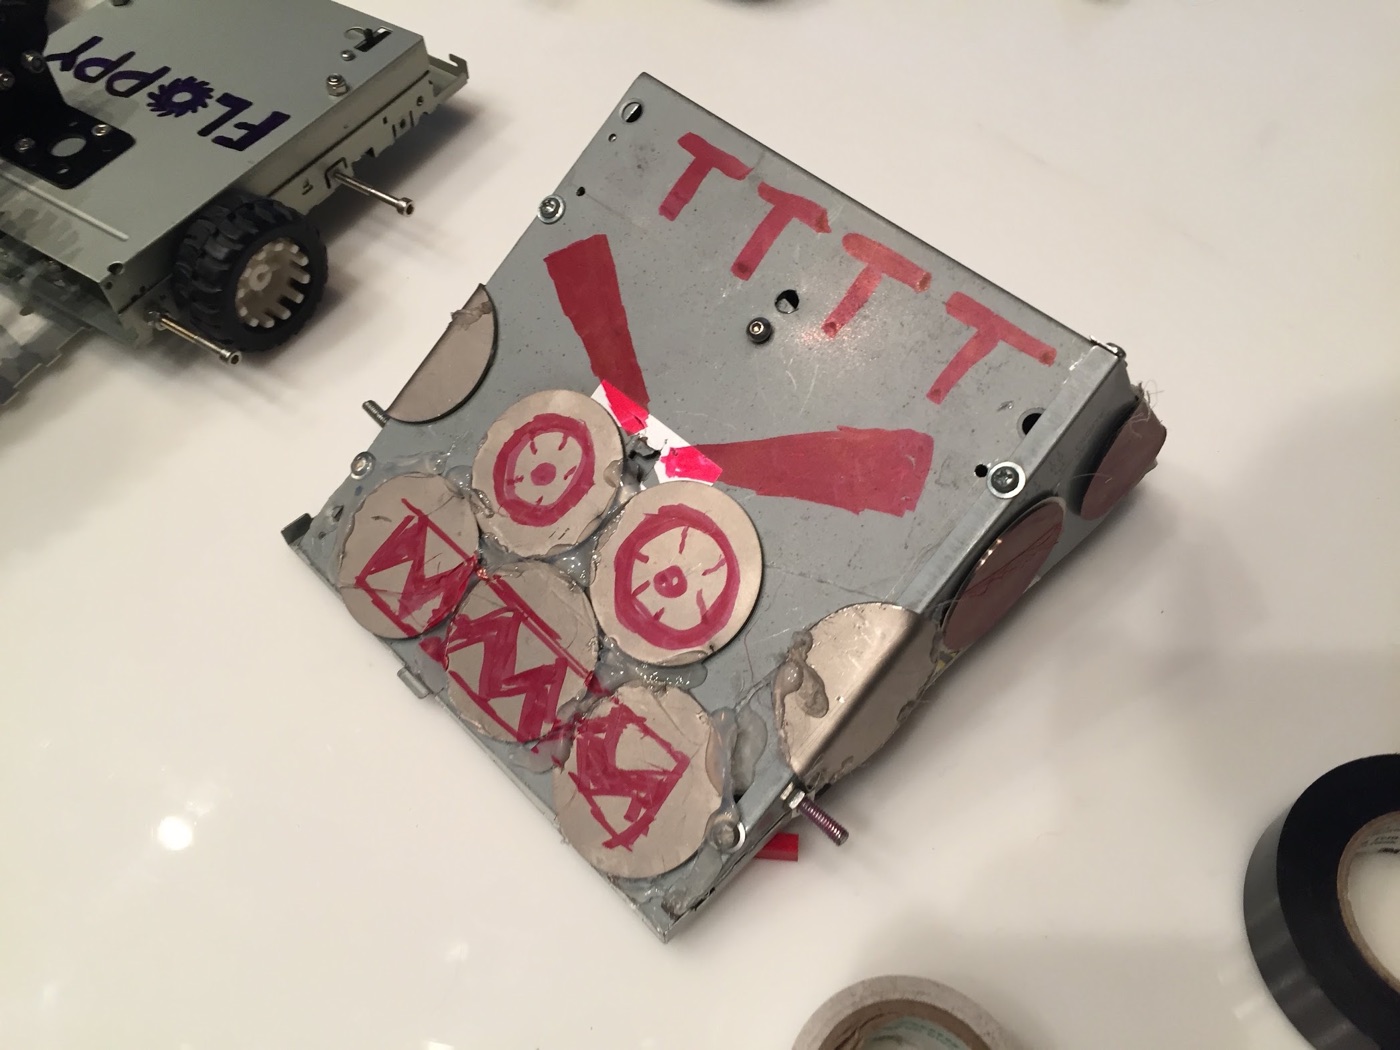
TTT
"Tres tristes trozos de tétanos" (three sad pieces of tetanus): a wedge built from the casing of an old DVD player.
Rodilla
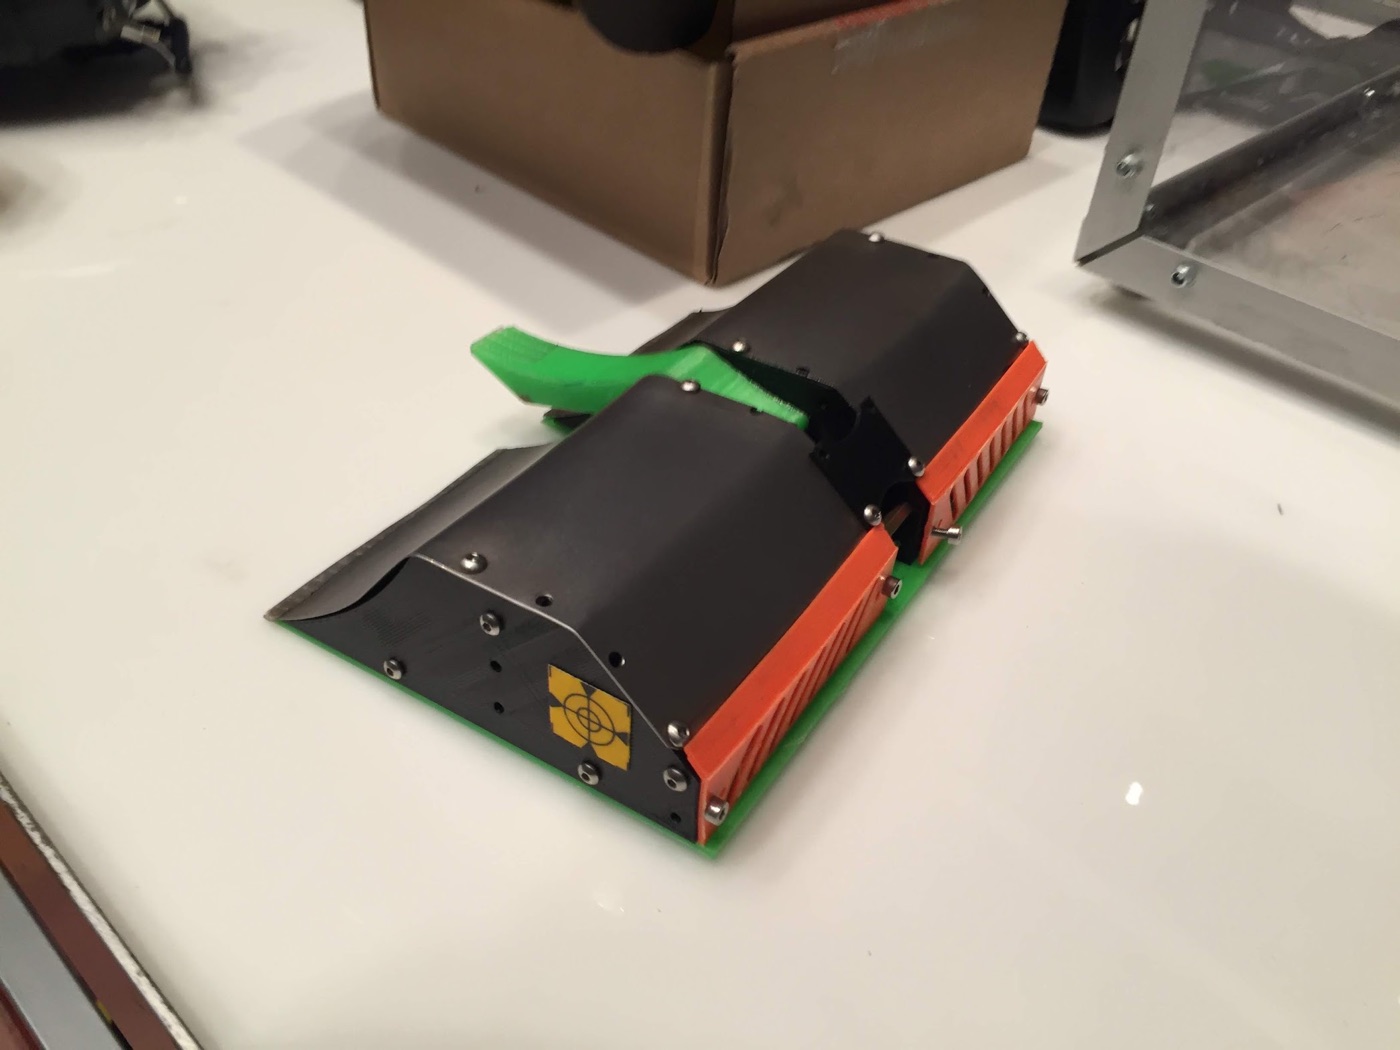
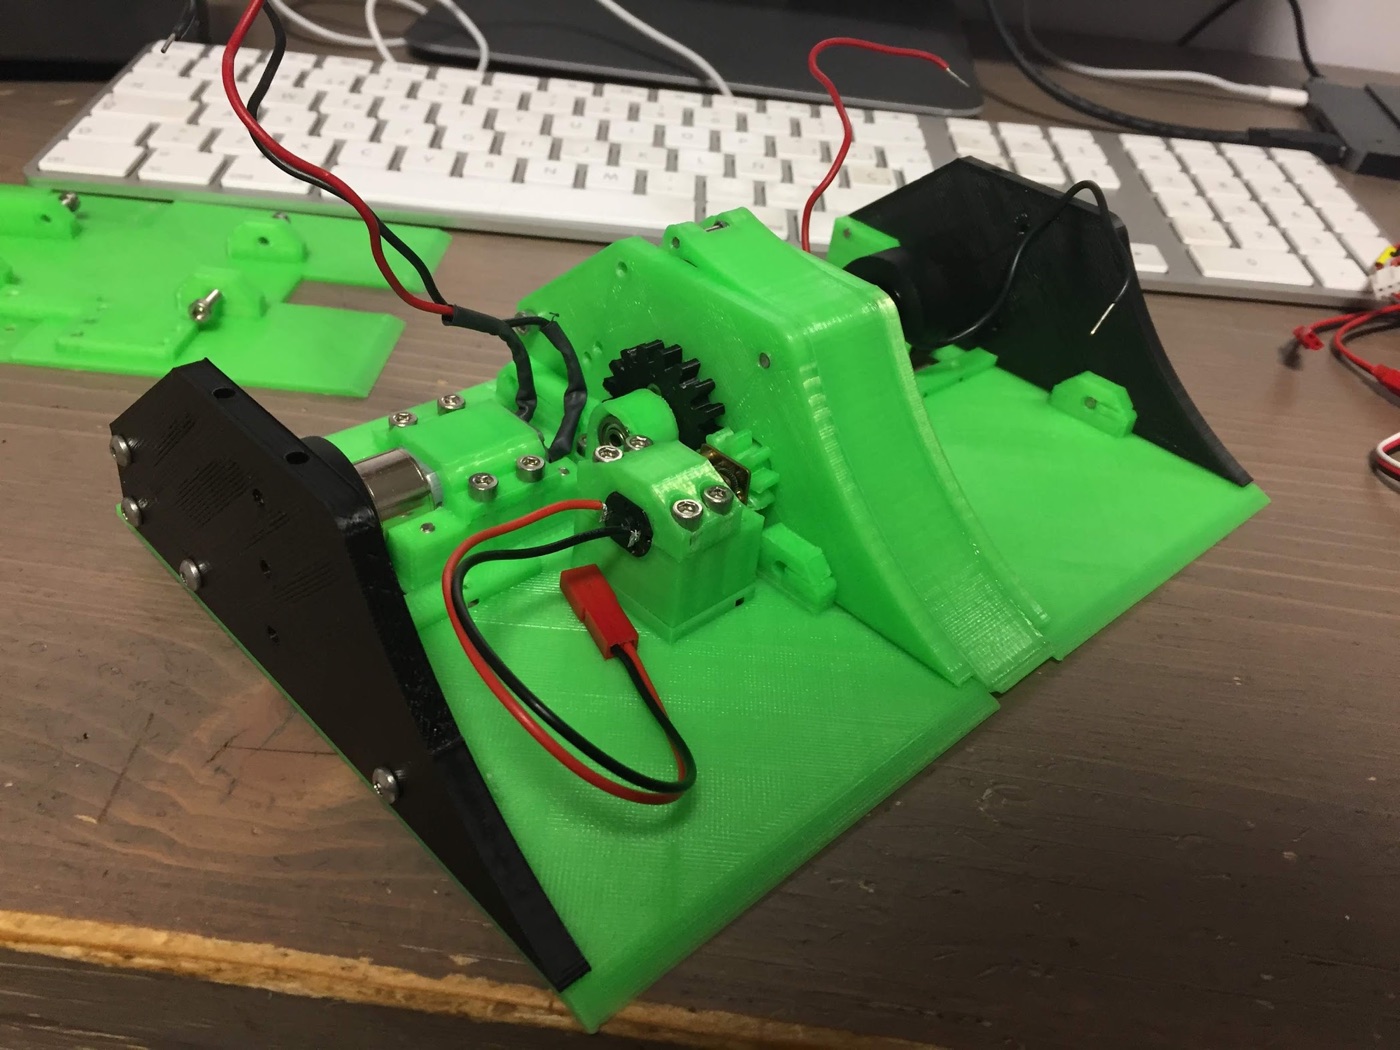
Flipper for OSHWDem 2018: a motor turns a cam that loads a spring, and its release throws the flipper up.
- 3D-printed chassis and gears; the STL files are in the repository.
Minio
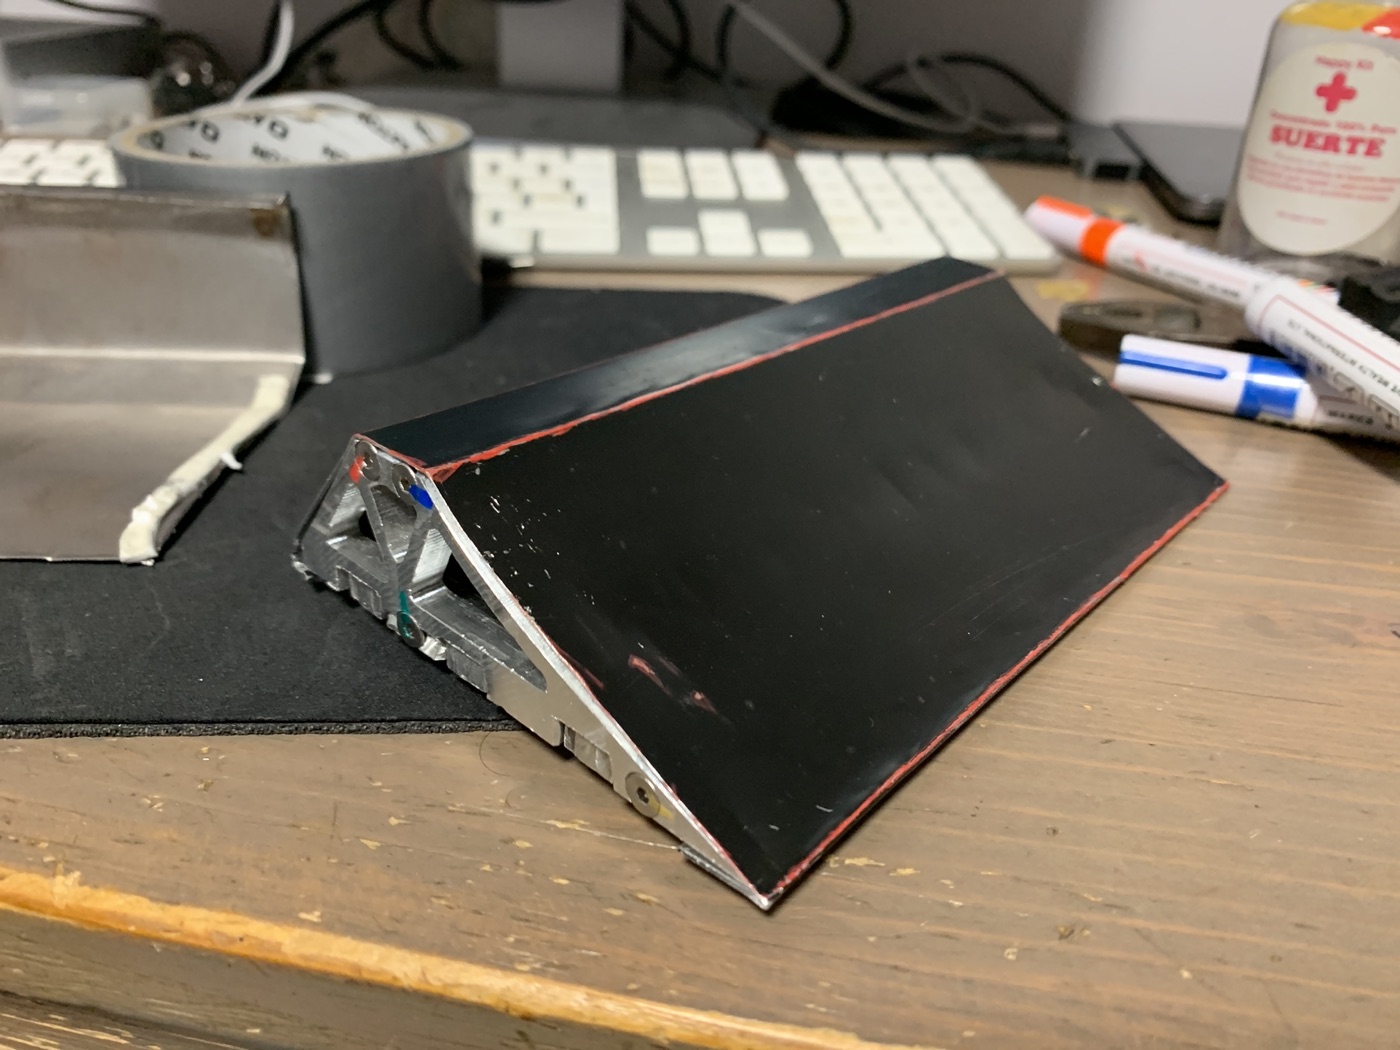
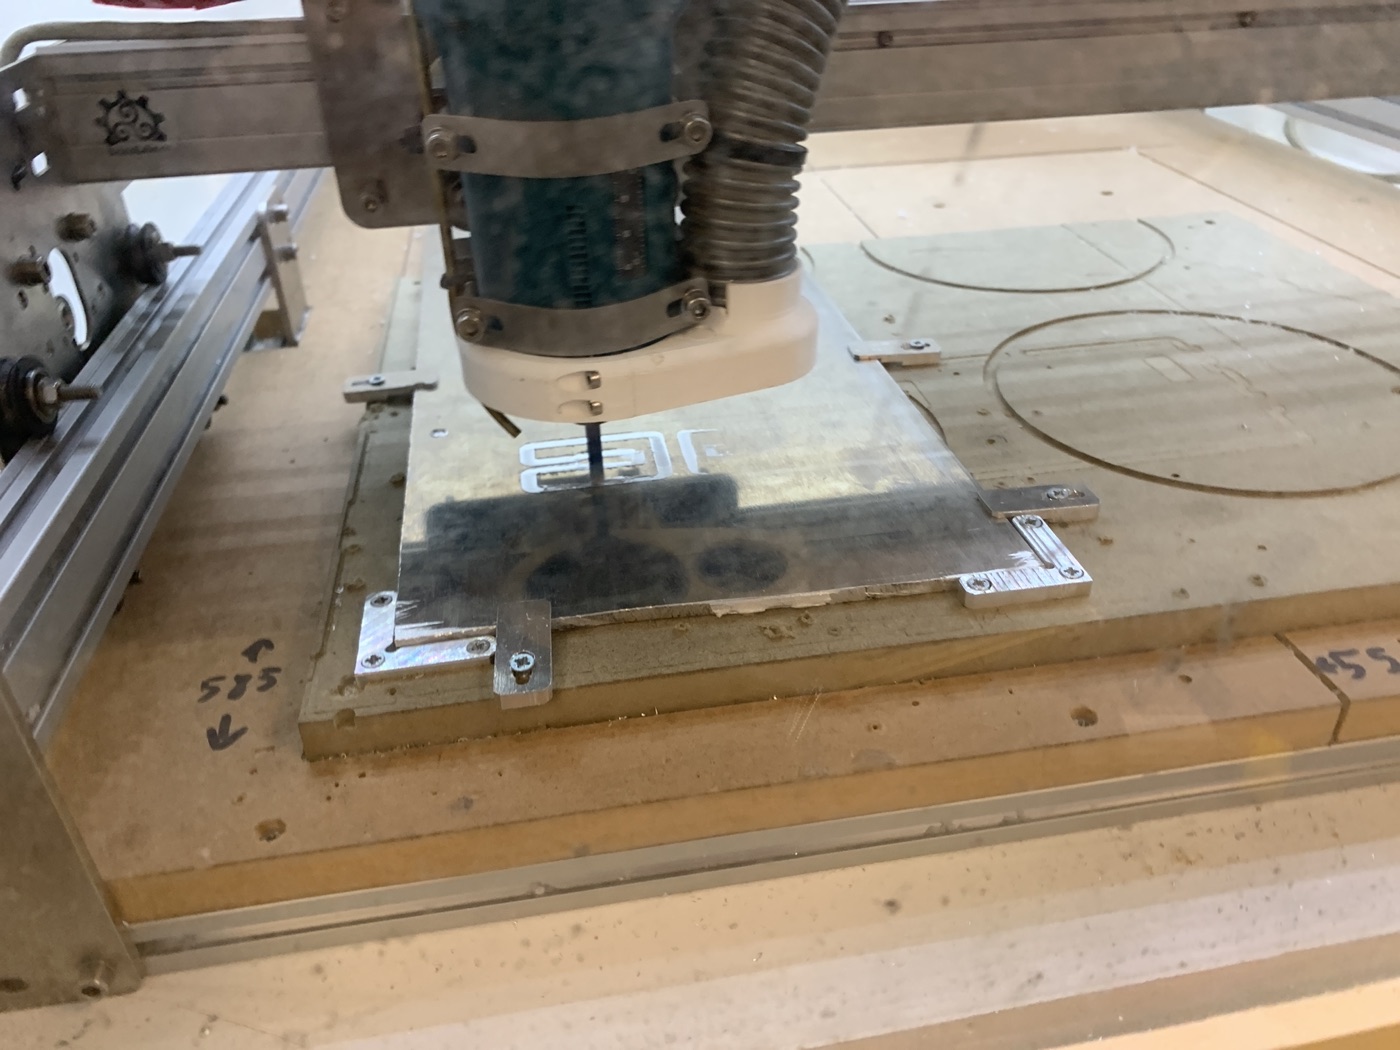
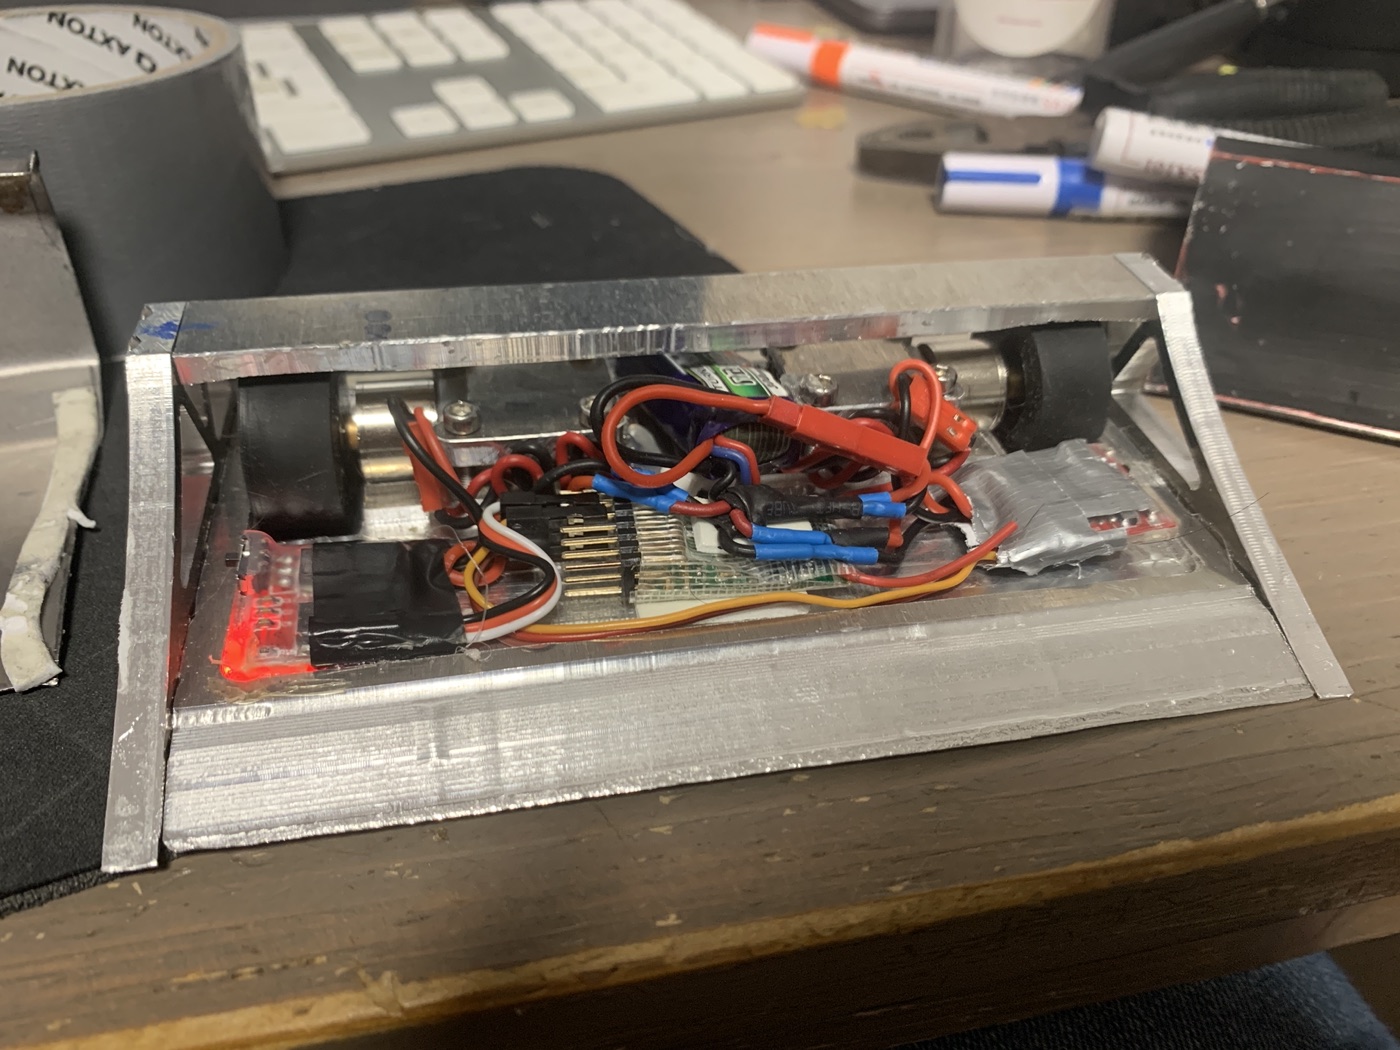
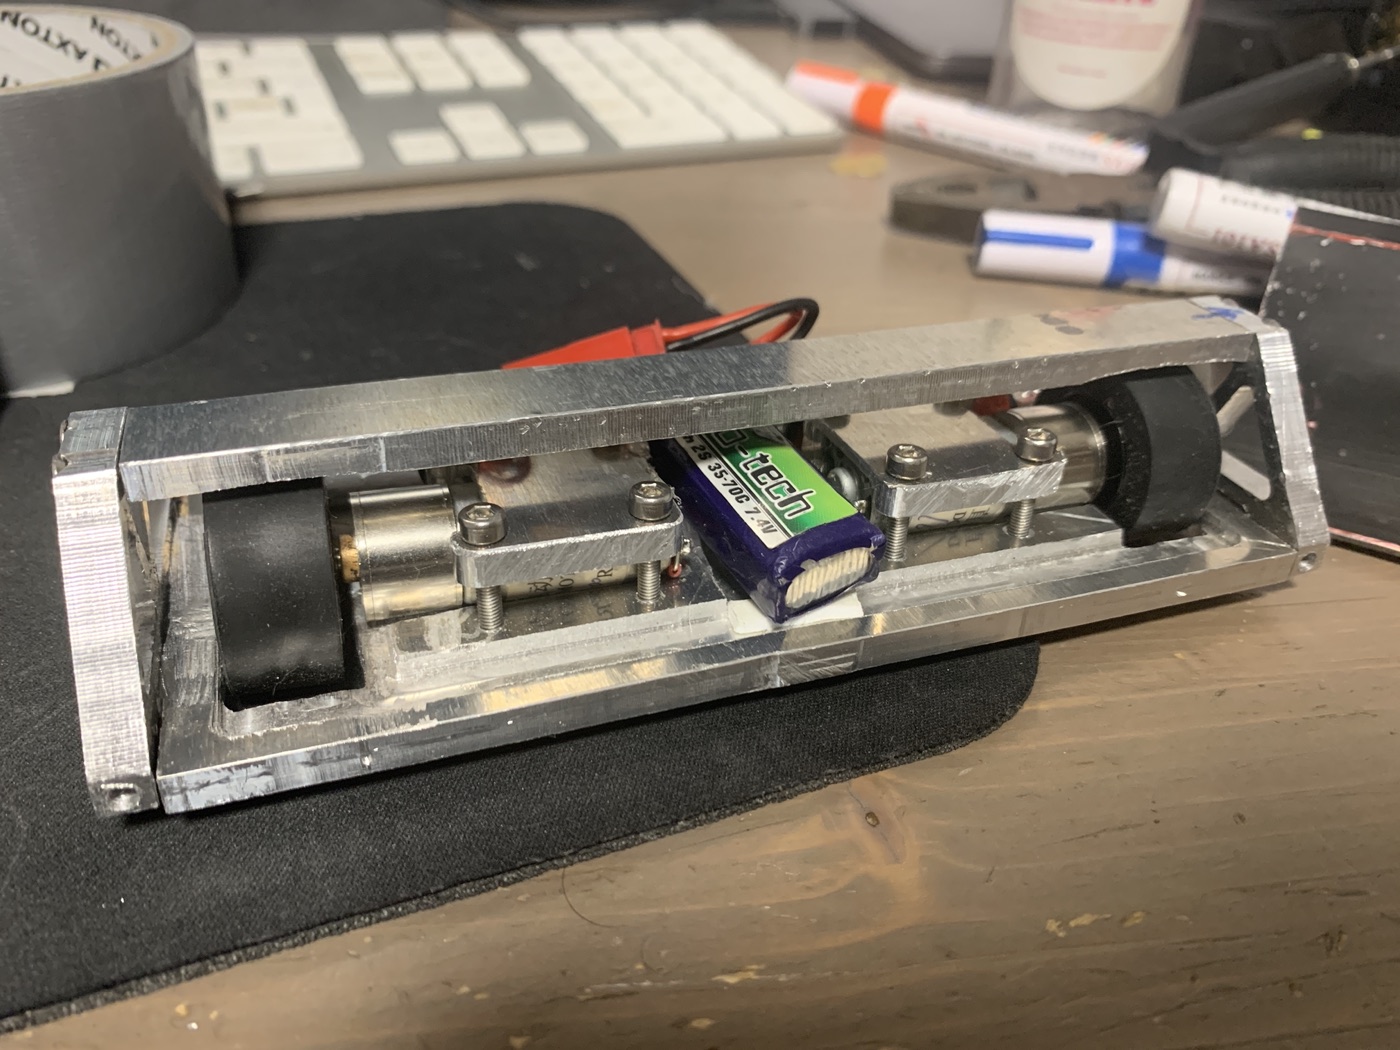
Wedge for OSHWDem 2019, milled entirely from aluminium on an eShapeoko with a Makita spindle at Bricolabs.
- 6 mm aluminium sides, 5 mm base and motor holders, and a 0.5 mm sheet cover.
- Two DC motors with Solarbotics RW2i wheels, RC speed controllers, a DSM2/DSMX receiver and a 300 mAh 2S LiPo.